本报告涉及的工作

Publications

PuzzleAvatar: Assembling 3D Avatars from Personal Albums

Yuliang Xiu, Yufei Ye, Zhen Liu, Dimitrios Tzionas, Michael J. Black

SIGGRAPH Asia 2024 · ACM TOG

UP2You: Fast Reconstruction of Yourself from Unconstrained Photo Collections

Zeyu Cai, Ziyang Li, Xiaoben Li, Boqian Li, Zeyu Wang, Zhenyu Zhang, Yuliang Xiu

ICLR 2026

ETCH: Generalizing Body Fitting to Clothed Humans via Equivariant Tightness

Boqian Li, Haiwen Feng, Zeyu Cai, Michael J. Black, Yuliang Xiu

ICCV 2025 · Highlight

ETCH-X: Robustify Expressive Body Fitting to Clothed Humans with Composable Datasets

Xiaoben Li, Jingyi Wu, Zeyu Cai, Siyuan Yu, Boqian Li, Yuliang Xiu

ECCV 2026

OmniFit: Multi-modal 3D Body Fitting via Scale-agnostic Dense Landmark Prediction

Zeyu Cai, Yuliang Xiu, Renke Wang, Zhijing Shao, Xiaoben Li, Siyuan Yu, Chao Xu, Yang Liu, Baigui Sun, Jian Yang, Zhenyu Zhang

ECCV 2026

GaussiAnimate: Rig Animatable Categories with Level of Dynamics

Jiaxin Wang, Dongxin Lyu, Zeyu Cai, Zhiyang Dou, Cheng Lin, Anpei Chen, Yuliang Xiu

SIGGRAPH Asia 2026

Human3R: Everyone Everywhere All at Once

Yue Chen, Xingyu Chen, Yuxuan Xue, Anpei Chen, Yuliang Xiu, Gerard Pons-Moll

ICLR 2026

DirtyMoCap: Robust Motion Capture from Unconstrained Markers

Long Wang, Shuting Zhao, Shen Yan, Siyuan Yu, Xiaoben Li, Zeyu Cai, Yumeng Hou, Yuliang Xiu

SIGGRAPH Asia 2026

Pose Flow: Efficient Online Pose Tracking

Yuliang Xiu, Jiefeng Li, Haoyu Wang, Yinghong Fang, Cewu Lu

BMVC 2018

SSDR: Smooth Skinning Decomposition with Rigid Bones

Binh Huy Le, Zhigang Deng

SIGGRAPH Asia 2012 · ACM TOG

论文与项目页面可点击标题访问 · SSDR 为方法引用

GaussiAnimate

Rig Animatable Categories with Level of Dynamics

Jiaxin Wang¹   Dongxin Lyu¹   Zeyu Cai¹˒²   Zhiyang Dou³   Cheng Lin⁴   Anpei Chen¹   Yuliang Xiu¹

¹ Westlake University    ² Nanjing University    ³ The University of Hong Kong    ⁴ Macau University of Science and Technology

Kinematic control
Non-rigid deformation
Animatable 4D assets
SIGGRAPH Asia 2026 · Conference Papers01 / 18

From Captured Motion to Editable Motion

Motivation
INPUT

A dynamic 3D asset

Temporally consistent Gaussian or mesh sequences.

GOAL

New skeletal motions

Intuitive control with non-rigid surface deformation.

A captured sequence records motion. An animation rig lets us change it.
Project teaser · Paper §1, §303 / 18

The Control–Deformation Gap

Motivation
Actors01 reconstructed motion and SMPL KNN LBS at the same open-leg pose
Reconstructed motionSMPL KNN LBS

Articulation is only
part of the motion.

A skeleton provides clear controls, but simple skinning misses clothing deformation.

The surface must respond to motion beyond rigid joint transforms.

How can we retain skeletal control and deformation fidelity in one rig?
Actors01 · Original Blender comparison · Timeline frame 860 / source frame 49804 / 18

Skelebones

Representation

Inner skeleton

Intuitive articulation

Outer free-form bones

Local surface deformation

Animated surface

Geometry and appearance

An inner skeleton controls articulation. Outer bones approximate non-rigid surface motion.
ActorsHQ · Existing SMPL skeleton · Paper §306 / 18

Outer Bones from Surface Motion

Rig Construction
01

Explain the motion

Fit local rigid motion to a region.

02

Split where error is high

Initialize a new cluster from poorly explained motion.

03

Refine skinning

SSDR jointly refines weights and bone transforms.

Dense deformation becomes a compact set of free-form bone transformations.
VTO demonstration · Motion clustering and SSDR · Paper §3.108 / 18

An Inner Skeleton from Skinning Evidence

Rig Construction
Original full-process construction animation · Paper Fig. 3 and §3.209 / 18

Across Categories and Representations

Results

One representation,
different assets.

Clothed humans

Reconstructed 4D Gaussians

Garments and animals

Temporally consistent meshes

Each asset has its own rig and motion database.

Applicable to articulated assets with a deformable exterior.
Project teaser · Cross-category results · Paper §4.316 / 18

Smooth Skinning Decomposition

SSDR

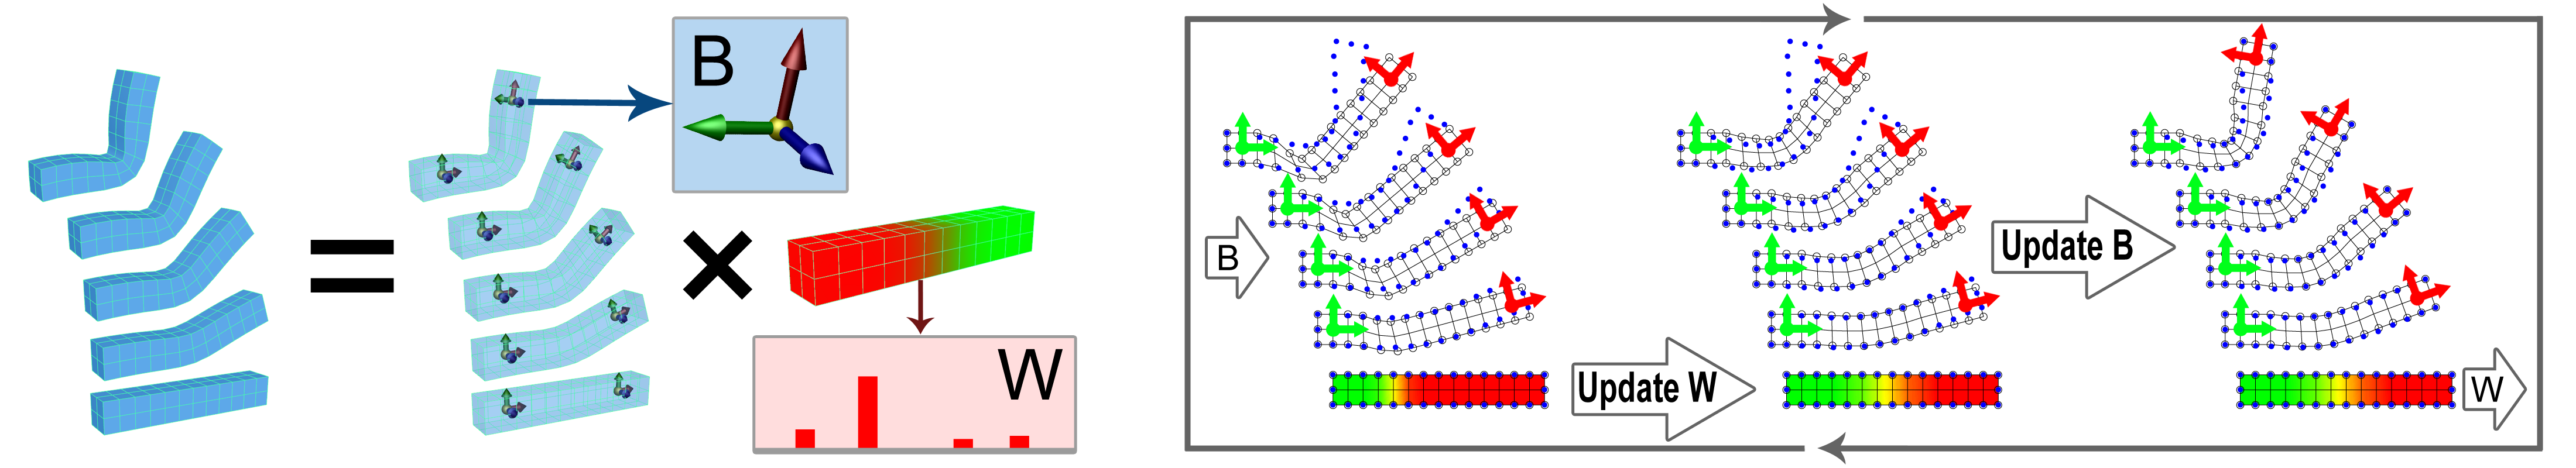
把示例形变分解为刚性骨骼变换 B 与稀疏蒙皮权重 W

SSDR teaser: example poses decompose into bone transformations B and weights W; alternate updates reduce reconstruction error minB,WE(B,W)=∑t∑i‖vit−∑jwij(Rjtpi+Tjt)‖2\min_{B,W} E(B,W)=\sum_t\sum_i\left\|v_i^t-\sum_j w_{ij}(R_j^t p_i+T_j^t)\right\|^2
wij≥0,∑jwij=1,‖Wi‖0≤K,Rjt∈SO(3)

B 骨骼变换 {R, T}

W 稀疏、非负、归一化权重

固定 B 更新 W ↔ 固定 W 更新 B
Binh Huy Le & Zhigang Deng · SIGGRAPH Asia 2012 · Eq. (2)

Results and Applications

SSDR
Binh Huy Le & Zhigang Deng · SIGGRAPH Asia 2012 · Full video
DirtyMoCap
Robust Motion Capture from Unconstrained Markers
and Construction of a Kung Fu Motion Dataset
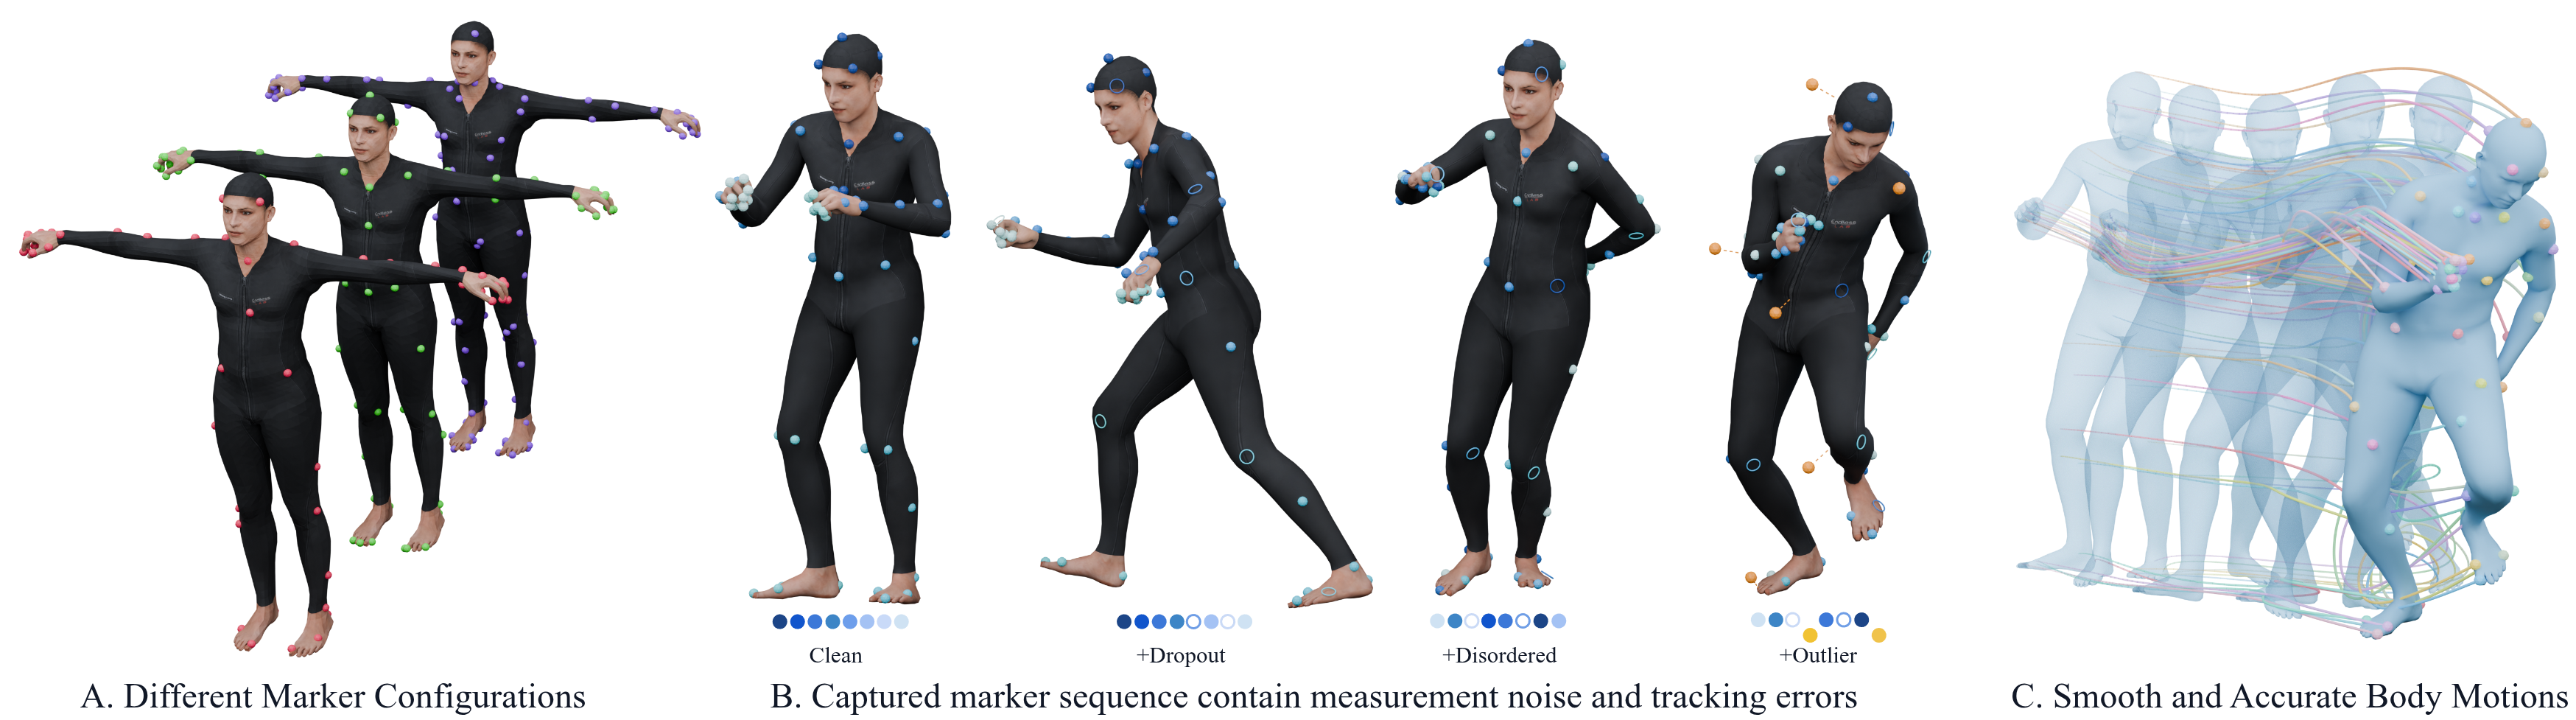
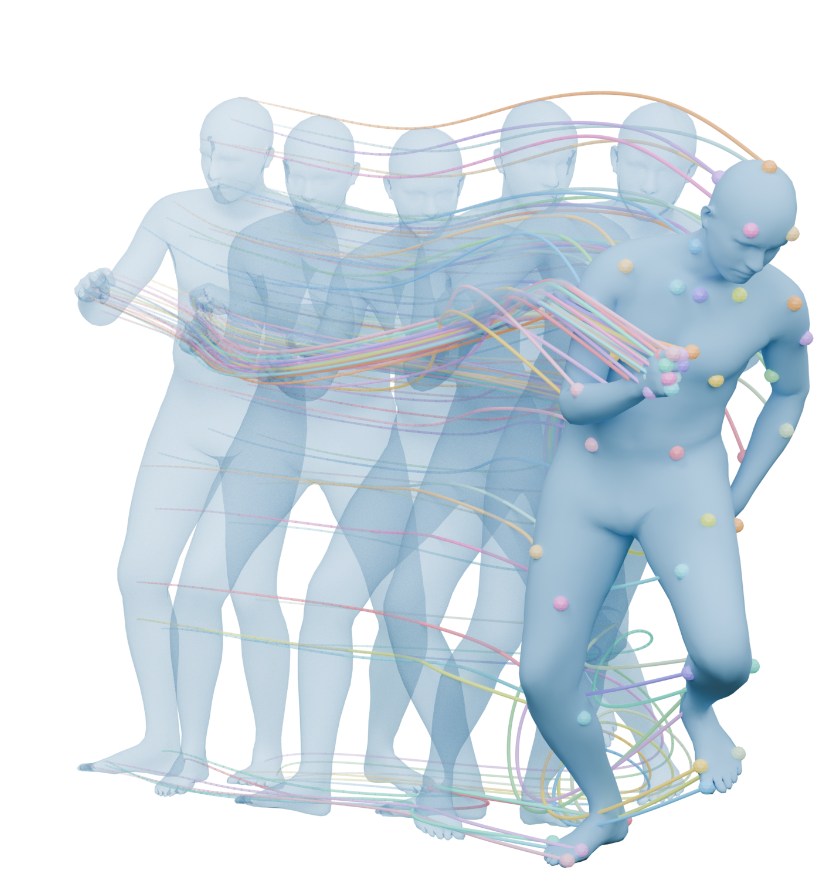
DirtyMoCap teaser: varied marker configurations, corrupted observations, and recovered body motion
01/16
Commercial MoCap System
Background
Vicon
0:00 / 1:19
Vicon marker configuration placeholder
Magesnik
0:00 / 1:15
OptiTrack marker configuration placeholder
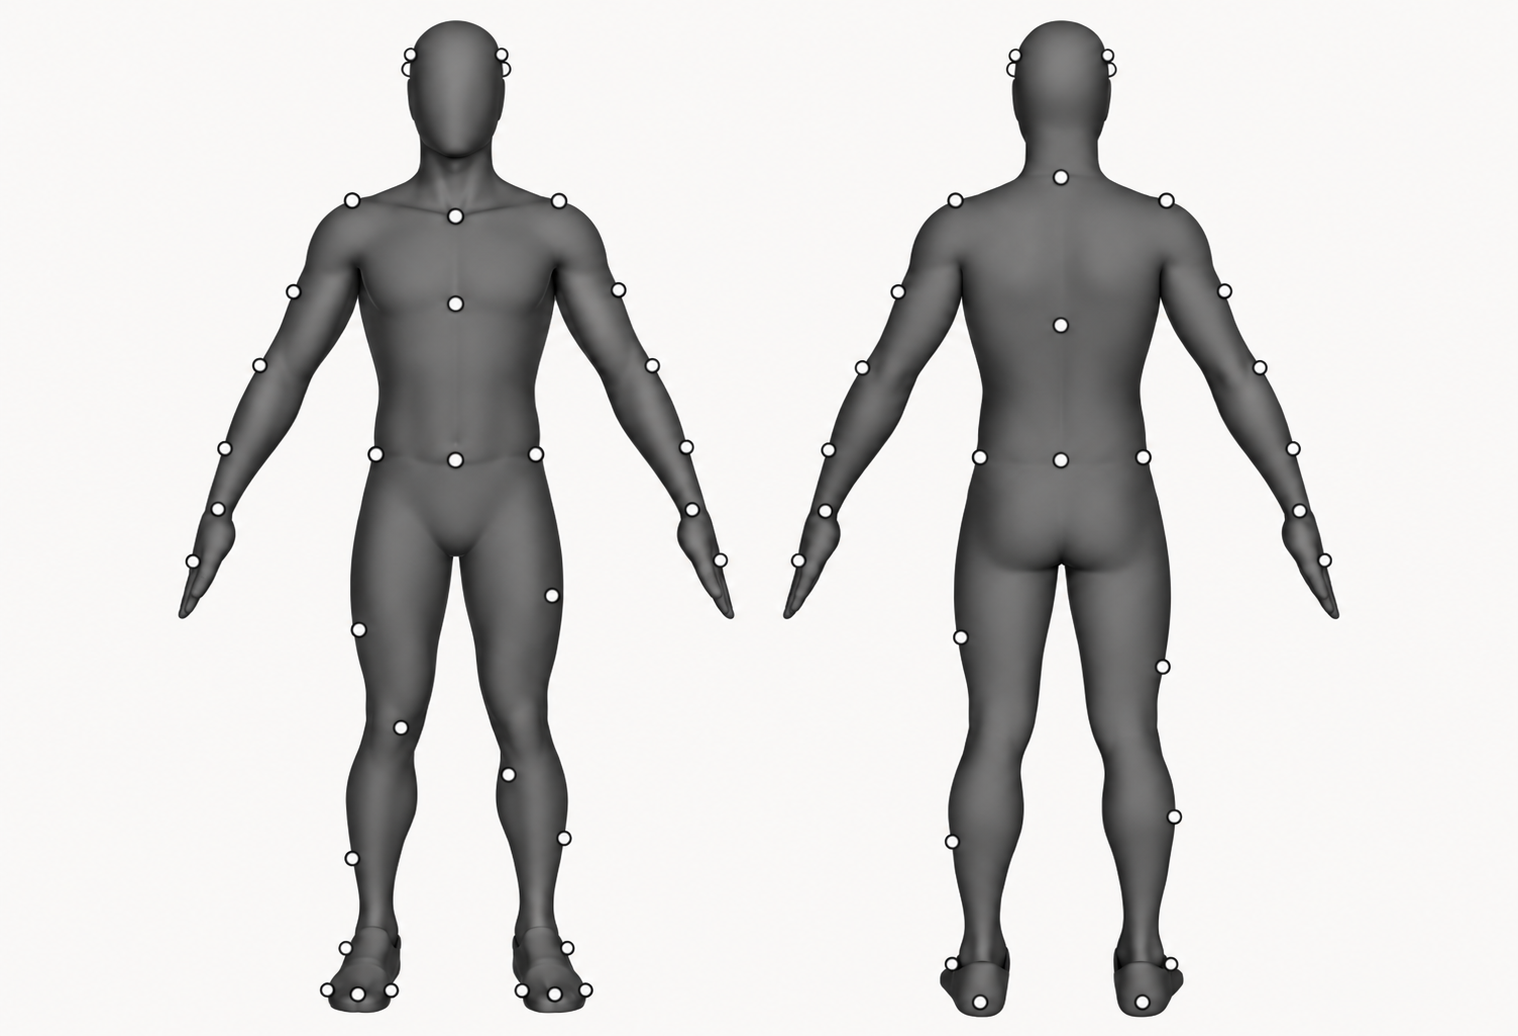
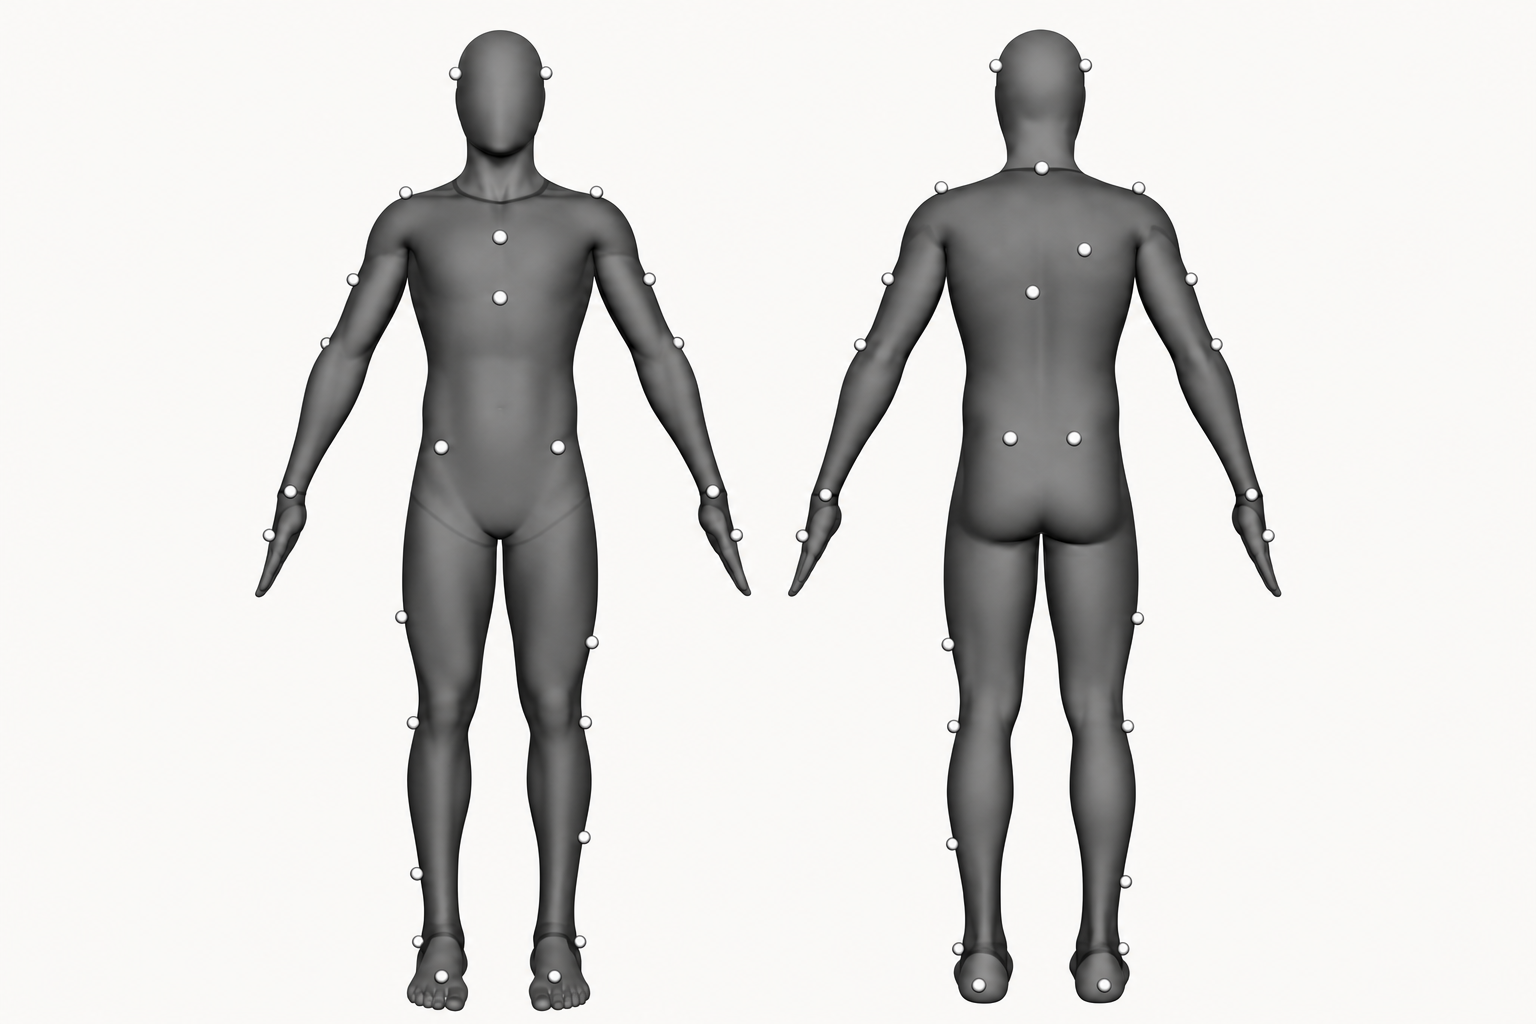
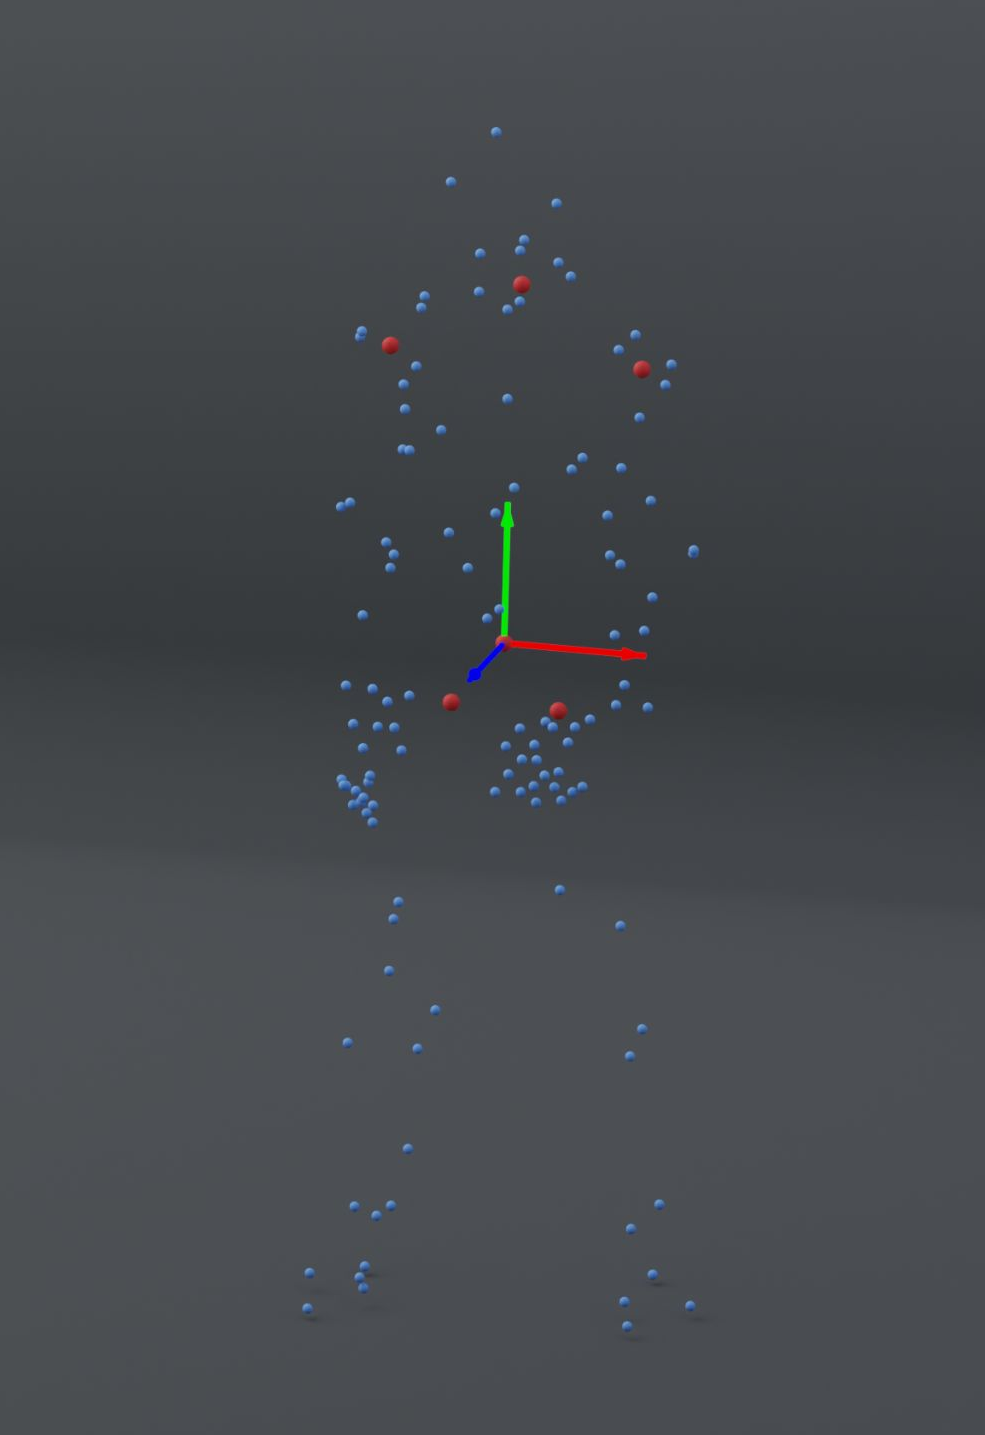
A marker configuration specifies where markers are placed on the body.
Unknown or incompatible marker configurations prevent direct use of standard automatic labeling and skeletal-solving pipelines.
03/16
From Controlled Capture to Unconstrained Markers
Background
0:00 / 0:25
0:00 / 0:14
Placement errors and occlusion introduce marker noise
Jitter · Dropout · Ghost
04/16
From Controlled Capture to Unconstrained Markers
Background
0:00 / 0:07
0:00 / 0:03

Markers that reappear after occlusion may also receive new labels, breaking temporal consistency.

Motion reconstruction must also accommodate different marker configurations across captures.

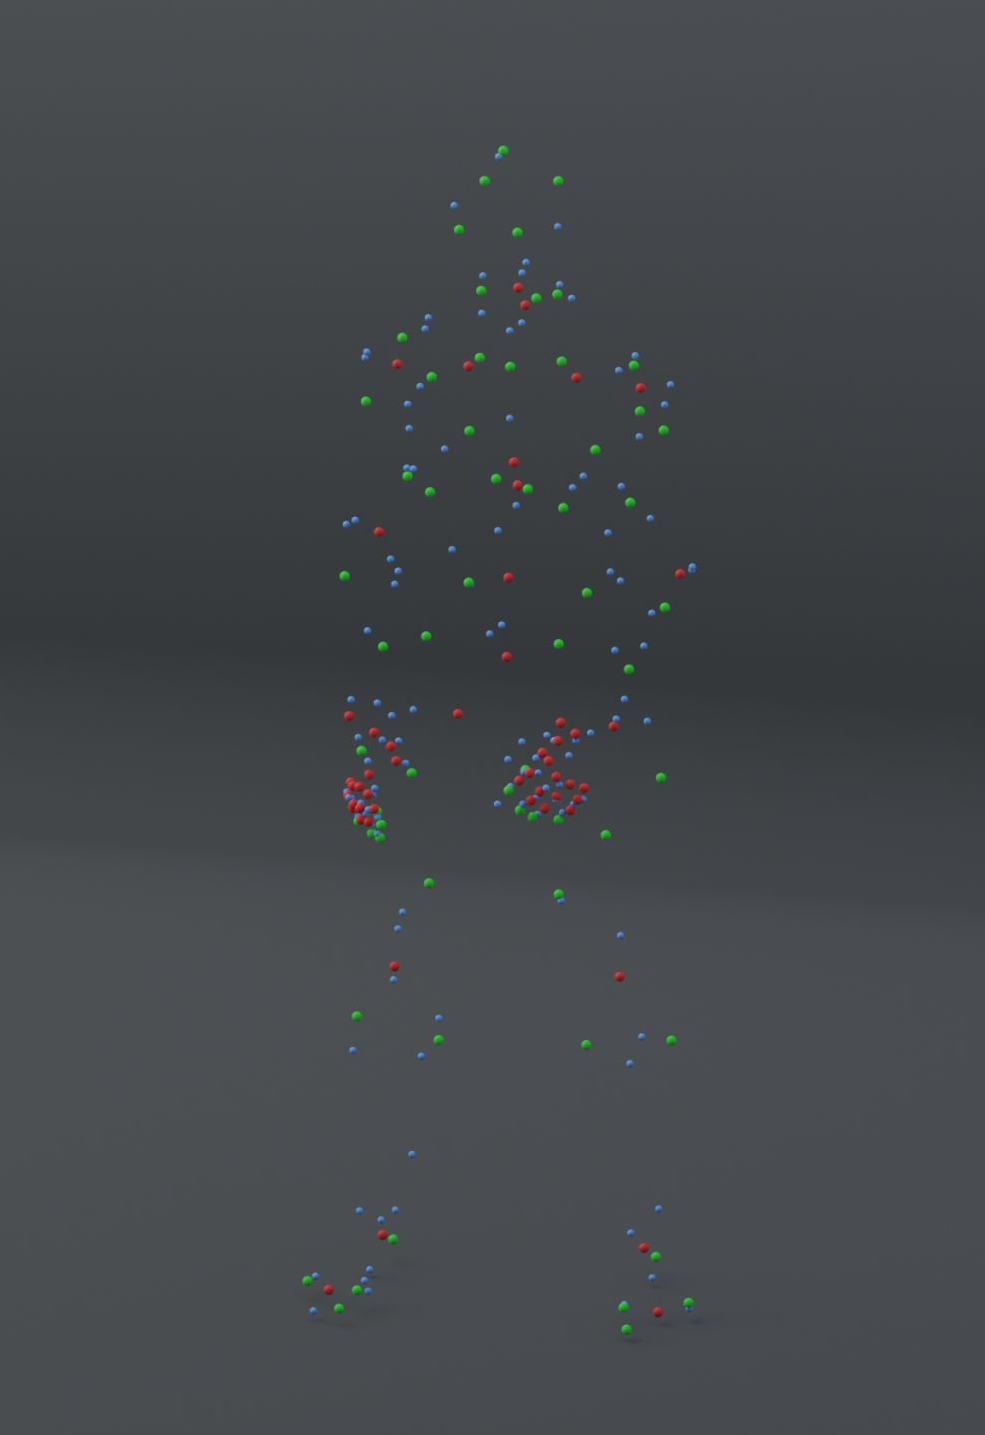
Unconstrained Markers: dirty and unordered markers under different unknown marker configurations.

05/16
Raw Kung Fu Motion Captures
Motivation
134
motion sequences
22
martial-arts styles
~180
minutes of motion
We obtained raw marker recordings of traditional Chinese martial arts, captured between 2013 and 2022.
Marker configuration metadata, marker identities, and marker-to-body correspondences are unavailable.
Our goal: Recover usable human motion from these raw recordings
and construct a standardized Kung Fu motion dataset.
0:00 / 1:23
0:00 / 0:50
0:00 / 0:55
0:00 / 1:33
07/16
DirtyMoCap
Contributions
Unconstrained Markers
Proxy Anchors
Human Motion
Auto-rotating · Drag to take control
52 joint anchors61 surface anchors
Canonical Proxy Anchors
Fixed anchor-to-body correspondences
0:00 / 0:04
08/16
Anchor Initialization
Method
A coarse-to-fine strategy for the first frame
6 anatomical anchors
113 proxy anchors
Six predicted anatomical anchors define the body-centric coordinate frame
The full set of predicted joint and surface anchors
● Markers   ● Joint anchors   ● Surface anchors
1
Coarse localization
Center markers by their median.
Predict pelvis, neck, hips, and shoulders.
2
Body-centric canonicalization
Use these six anchors to remove
global rotation and translation.
3
Fine anchor prediction
Predict 52 joint + 61 surface anchors,
then transform back to original coordinates.
Each prediction stage uses a Point Transformer
and a decoder with learnable anchor queries.
Why surface anchors?  Resolve bone-axis twist ambiguity and constrain body shape.
10/16
Differentiable and Learnable Solver
Method
Tracked anchorsA1:TKnown body correspondences
Weight predictorΨInput-dependent weighting policy
ObservationEobs   wcAnchor confidence
SmoothnessEsmooth   wsTemporal coherence
Pose priorEprior   wpDPoser-X
Differentiable
Gauss–Newton Solver
Jointly optimizeθ1:T pose · τ1:T translation · β shape
Recovered SMPL-H motion with colored proxy anchors
Recovered SMPL-H motion
Colored anchors constrain the motion.
End-to-end parameter supervision. Final pose, translation, and shape errors backpropagate through unrolled Gauss–Newton iterations to train Ψ.
12/16
Results on Synthetic Data
Experiments
Representative reconstructions across marker configurations and corruption types.
0:00 / 0:27
0:00 / 0:28
0:00 / 0:25
0:00 / 1:00
Each clip shows input markers, the DirtyMoCap reconstruction, and ground truth.
14/16
HKMALA-Motion Dataset
Dataset
0:00 / 0:50
0:00 / 0:55
0:00 / 0:38
0:00 / 0:13
134段动作sequences
22种拳术styles
≈180分钟minutes
8.4年采集跨度years · 2013–2022
≈8,500帧 / 每段frames / sequence

代表拳种 Selected styles

洪拳Hung Kuen
白眉拳Pak Mei
咏春拳Wing Chun
蔡李佛拳Choy Lee Fut
福建白鹤拳Fujian White Crane
螳螂拳Praying Mantis
鹰爪拳Eagle Claw
太极拳Taijiquan
八卦掌Baguazhang
通背拳Tongbeiquan

Historical marker captures → reusable SMPL-H motion

鸿胜蔡李佛 · Hung Sing Choy Lee Fut

杨式太极 · Yang-style Taijiquan

鹰爪翻子门 · Eagle Claw Fanzi

咏春拳 · Wing Chun

15/16
0:16 / 0:22
16/16

非理想观测下的人体数采